Status
SteamPeaks
ChartsSalesUpcomingPatchesNewsCalculator
New on SteamEvery app, DLC and depot the minute Steam creates itAppsEvery app on Steam, newest change firstPackagesSubs and bundles, and what each containsDepotsDepots, manifests and install sizesTagsSteam's user tags and the games under themDevelopers & publishersCompanies and their cataloguesTechnologiesEngines, SDKs and anti-cheat found in the filesChange historyEvery PICS changelist as it lands
SignalsNineteen readings of the whole catalogueCompareAny games side by sideRecordsAll-time peaks and the days they were setReportsWeekly and monthly write-upsAlerts & newsroomWatch a game, get told when it movesSteam statusIs Steam up, right nowWeb API explorerTry the endpoints in the browser
NewsSteam's own announcements and the sales calendarCalculatorWhat a Steam account is worth, and its pile of shame
/
Sign in
/
SteamPeaks
The ultimate resource for Steam data.
ExploreChartsSalesSales and festsUpcomingPatchesNewsRecordsTrendingSignals
DatabaseAppsPackagesDepotsTagsDevelopersTechnologiesChange history
ToolsCalculatorCompareSearchAlertsSteam statusAPI
SiteMethodologyFAQDiscordSupportSign in via Steam
Not affiliated with Valve or Steam. Game names and artwork belong to their owners. All times UTC.
PrivacyCookiesFair useStatus
JOY OF PROGRAMMING - Software Engineering SimulatorNewsThe Robot Arm
Community

The Robot Arm

JOY OF PROGRAMMING - Software Engineering Simulator · published 12 Nov 2023, 16:58 UTC

All newsPlayers around this dateRead on Steam

First, let me thank everyone for a very successful Steam Next Fest. Your support really means a lot. As we are nearing the Early Access release of JOY OF PROGRAMMING (the exact Date in Q1 2024 will be revealed soon), it's time to shorten the wait and show off another programmable device! Today we'll look at a programmable robot arm with inverse kinematics.

With the integrated IK system, you do not have to apply torque control to the individual motors of the arm, but rather can use a local coordinate system to directly set the desired position of the arm's grabber. Then you can pick-up most items, move the arm somewhere else and finally drop the item you are a carrying off again.
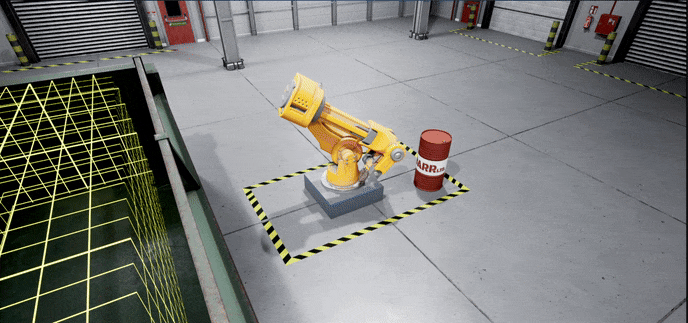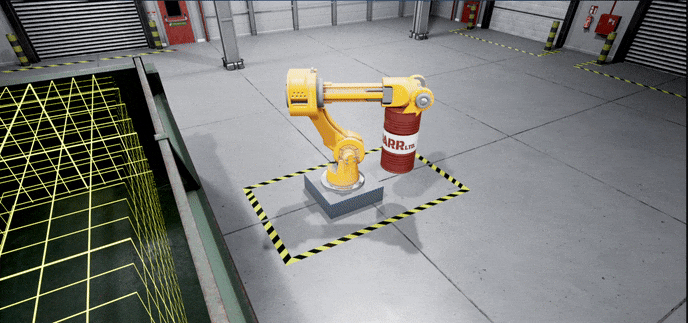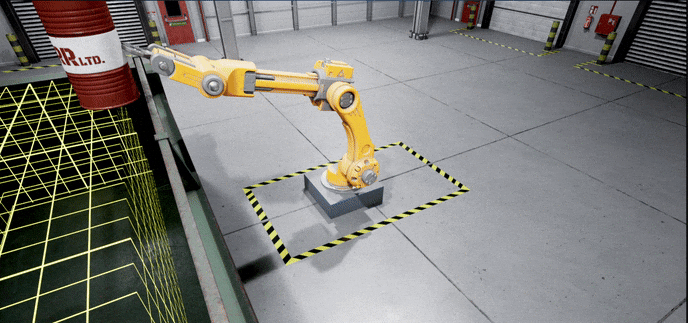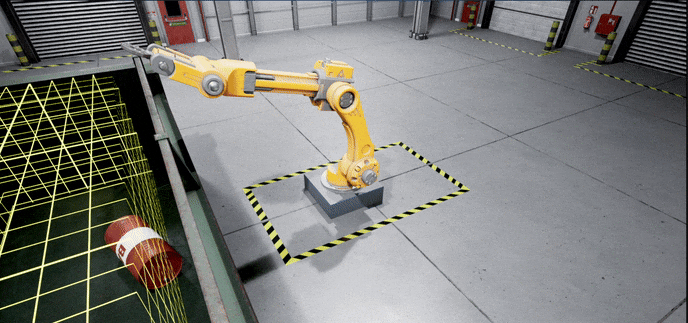

(Yeah, we don't talk about the clipping)

Using the robot arm is similar to using any other object in JOY OF PROGRAMMING:


arm = RobotArm.find("arm1")
#set position in local XYZ (forwards, right, up)
arm.set_grabber_location([1,0,1])
sleep(3) # wait to arrive
arm.pickup() # grab item
#change position
arm.set_grabber_location([-1,0.5,1.5])
sleep(3) # wait to arrive
arm.release() #drop off item

Happy Coding!

More from JOY OF PROGRAMMING - Software Engineering Simulator

Other announcements

All news
In-game event31 Aug 2025Small free content updateWhile I am currently quite busy with the development of my second game Card Coder, I did take some time to create a small content update for JOY OF PROGRAMMING. In particular, this update includes two new levels in the Driving category where you have to setup speed traps with the help of a RangeFinder or a SmartCamera respectively. And if a car is too fast, this is how you handle that situation…Community24 Jul 2025Games Forged in Germany FestI'm happy to announce that both of my games were selected for the Games Forged in Germany Fest. To celebrate the occasion, JOY OF PROGRAMMING is 30% off and the Demo for my upcoming card-building roguelike Card Coder is being released today ! Be sure to check out both games and the other titles featured in the fest!Game update28 Jan 2025Patch 1.0.2- improved objective description in CaesarCypher and CraneLift levels - fix in level Triangulation that caused commands to be counted multiple times - fixed "key not found" error in "Fibonacci" and "E-Mail validation" level - Improved log window: a) Increased opacity. b) Clicking a line copies it to the clipboard. - minor bug fixes